INPO automated recycling bin
A sensor-driven sorting prototype, built through two competition iterations with a project partner.
Sense the material. Move the item.
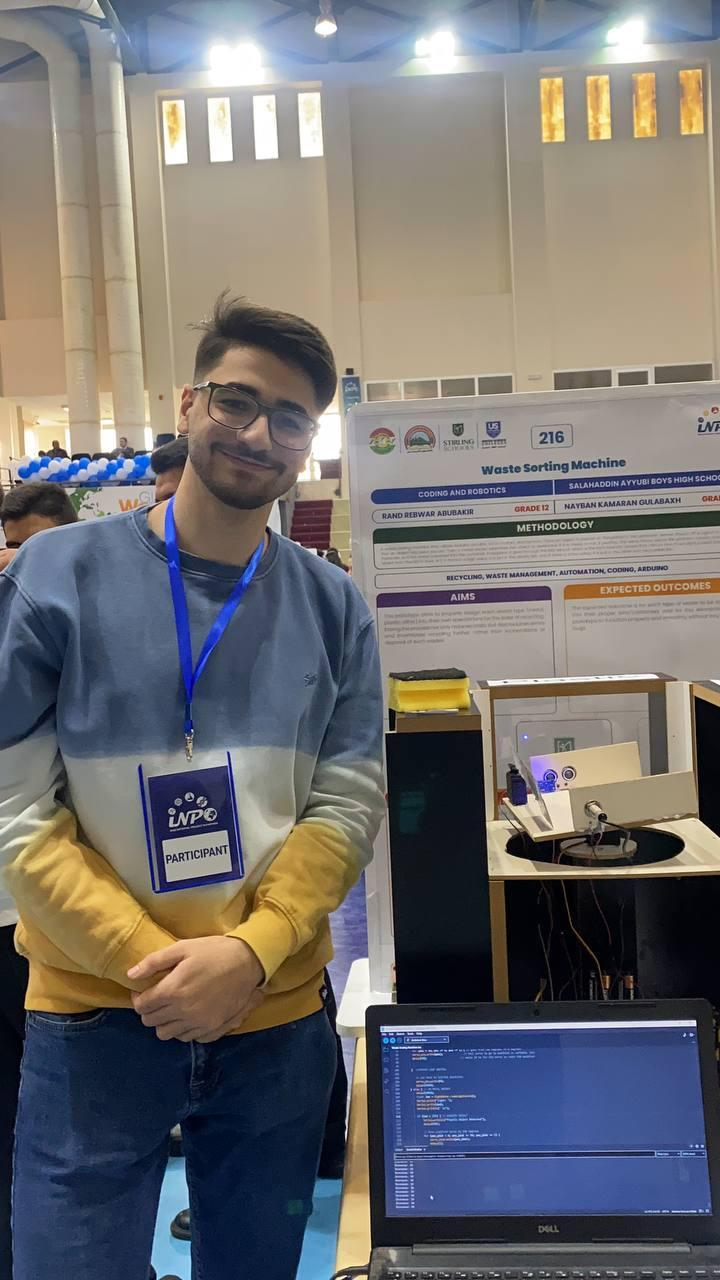
Working as a two-person team, we designed, coded, tested, and built a bin that sorts incoming items into metal, plastic, or other compartments. The prototype combines material sensing with a rotating platform and a push mechanism.
Connect classification to actuation.
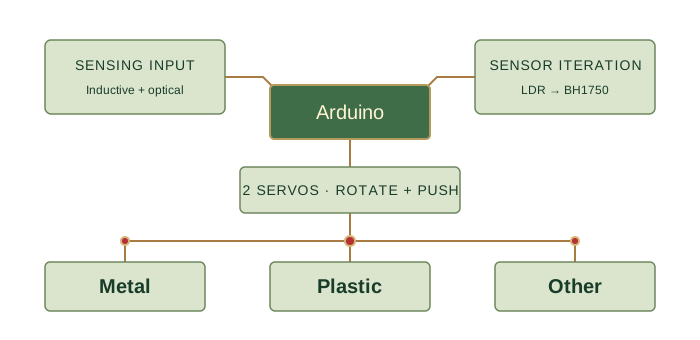
The Arduino-based classifier uses three active sensor inputs, including inductive and optical sensing, to identify the material category. Two servos coordinate the physical sorting process: rotating the platform toward the selected compartment, then pushing the item into it.
This project brought together sensor input, embedded control logic, and electromechanical operation in one working prototype.
Improve the input before tuning the output.
A noise-prone light-dependent resistor made optical detection inconsistent. I replaced it with a BH1750 digital light sensor to improve detection consistency.
The sensor change was a concrete hardware iteration toward more dependable classification.
From prototype to public demonstration.
We presented the project to judges, journalists, and public visitors at Iraq’s National Project Olympiad, where entries were evaluated on their pitch, innovation, and practical applicability. The project received Silver in 2023 and Gold in 2024 after further design improvements.
The experience combined hands-on engineering with explaining the design, its purpose, and its operation to a public audience.